Is the Viral Octopus Useless Box Real? the Surprising Tech Behind the Animatronic Craze
 By Robert Thorne
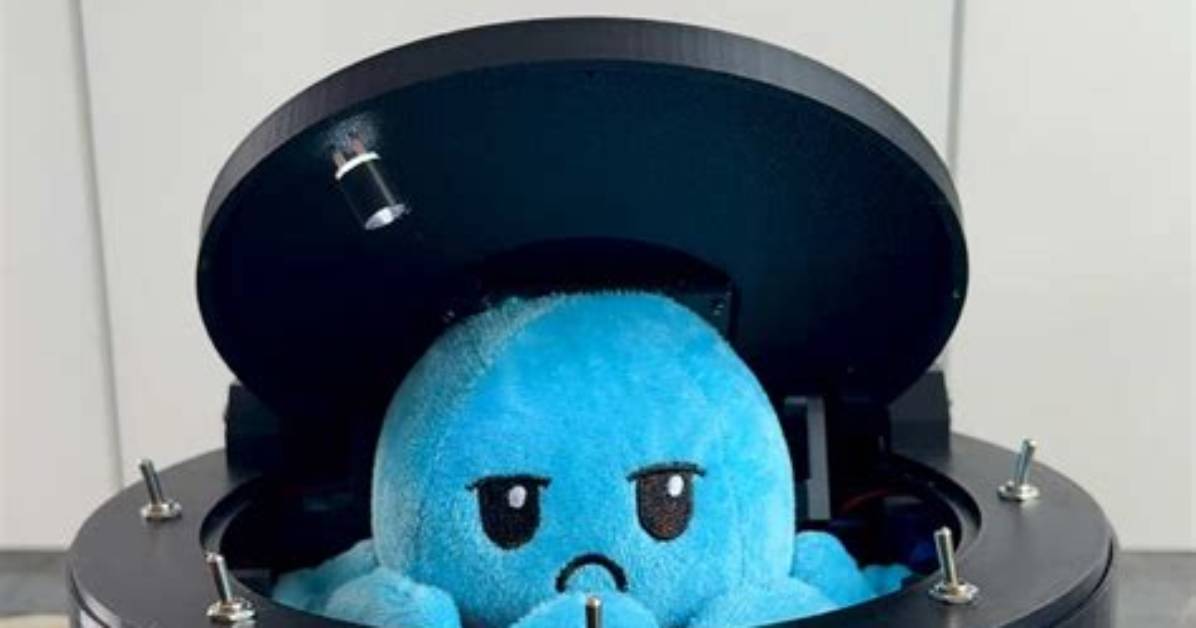
For makers determined to own a genuine animatronic useless machine, constructing one has become an accessible weekend challenge due to modern maker tools. The community has cataloged several workable iterations across platforms like Printables, Thingiverse, and GitHub.
The build requires four foundational phases:
1. Printing the Skeleton and Enclosure:
The core chassis requires a rigid structure to absorb the counter-torque of several servos pulling simultaneously. Printing the housing in PLA or PETG provides adequate rigidity. For the vertebra segments, resin printing using tough or flex resin creates the smoothest cable guide holes, preventing the braided spectra line from wearing through the conduit paths over hundreds of cycles.
2. Silicone Casting and Demolding:
Molds must be designed with two halves and a central core rod that leaves an open cavity inside the tentacle for the spine. Degassing the silicone inside a vacuum chamber before pouring eliminates microscopic air bubbles that can cause tears when the tentacle bends sharply.
3. Servos and Electrical Wiring:
Do not use cheap micro-servos with nylon gears. The resistance of stretching dense silicone quickly strips plastic teeth. Builders should specify metal-gear servos rated for at least 2.5 kg-cm of torque at 5V. Powering the servos directly from an Arduino's onboard regulator will cause voltage drops and brownout resets; an external 5V 3A DC power supply is mandatory.
4. Tuning the Microcontroller Code:
Linear movements make mechanisms look artificial. By using cubic easing algorithms or sine wave positioning within the microcontroller code, the tentacle decelerates smoothly as it nears the switch and accelerates when recoiling. Adding random wait states or variable speeds gives the impression of hesitant curiosity, transforming a basic circuit into an emotive desk companion.
Robert Thorne covers electric vehicle innovations, autonomous driving systems, global mobility trends, and automotive engineering developments.
